Read the work before it runs.
Inspect the workflow files, resolve inputs and check the plan without launching the native applications.
 schemaxis/Agent’s Hands
01 / No remote code execution by the AI
The template holds the operations, limits and checks. The parameter file supplies the values that vary. Together they define a job for Schemaxis. Click either file to inspect it, or change c and watch the parameter file update.
SchemaxisBind parametersData flow: the parameter values supply the polynomial in this example. For file-based jobs, Schemaxis captures authorised source data and passes it to the declared app operations.
Enable JavaScript to switch between files. Exact sources are linked below.Recorded binding and planning only; application launches: 0.
The exact template bundle contains template.json and its referenced workflow.json recipe. The separate parameter file selects one job. An AI can create the bundle and values; later operators reuse the bundle and change only the values. The graph groups the manifest and recipe as “Workflow Template”.
Core 68e139a bound and planned c = −2 and c = −3 without launching SymPy. The page only switches retained files or generates a local file preview. It does not contact Schemaxis, submit files, run applications, verify new results or create receipts. Execution and fresh result checks happen separately in a supported environment.
The file-template example is the self-operated core contract. The hosted strict interface has its own admission contract. This single-app example does not qualify arbitrary multi-app pipelines or a hosted template-upload endpoint.
Exact template manifest ↗ · Exact recipe ↗ · Full workflow reference ↗First example · ParaView from saved results
Existing DrivAer and pitzDaily views, rendered by Schemaxis driving ParaView 5.13.3. Native HELYX 4.6.0 ran the simulations independently. These are saved-result illustrations, not hosted solver capabilities.
The data owner supplies saved fields and a declared ParaView recipe. Inspect supported operations and the plan before rendering. This preview uses already recorded views; it does not upload geometry, create a plan for a new CFD case or run a solver.
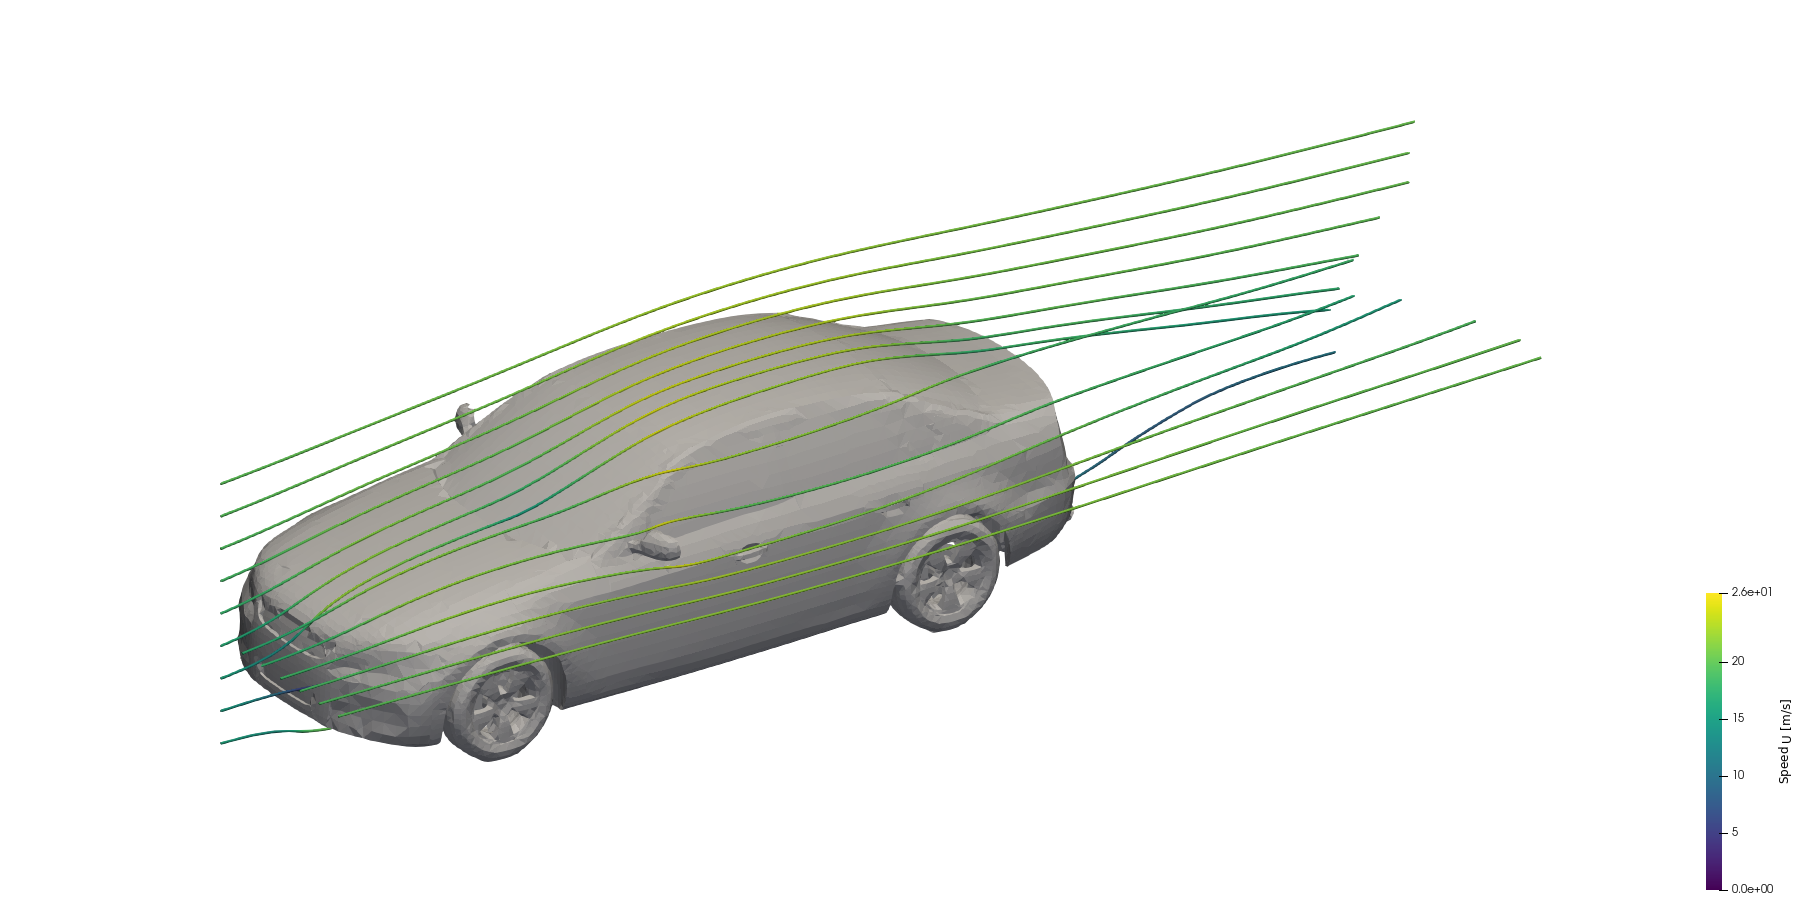
Saved HELYX result at 20 m/s; ParaView post-processing by Schemaxis. Steady-field curves, not particle paths. Coarse mesh, no boundary layers; residual targets were not met. Illustrative, not a validated aerodynamic prediction.
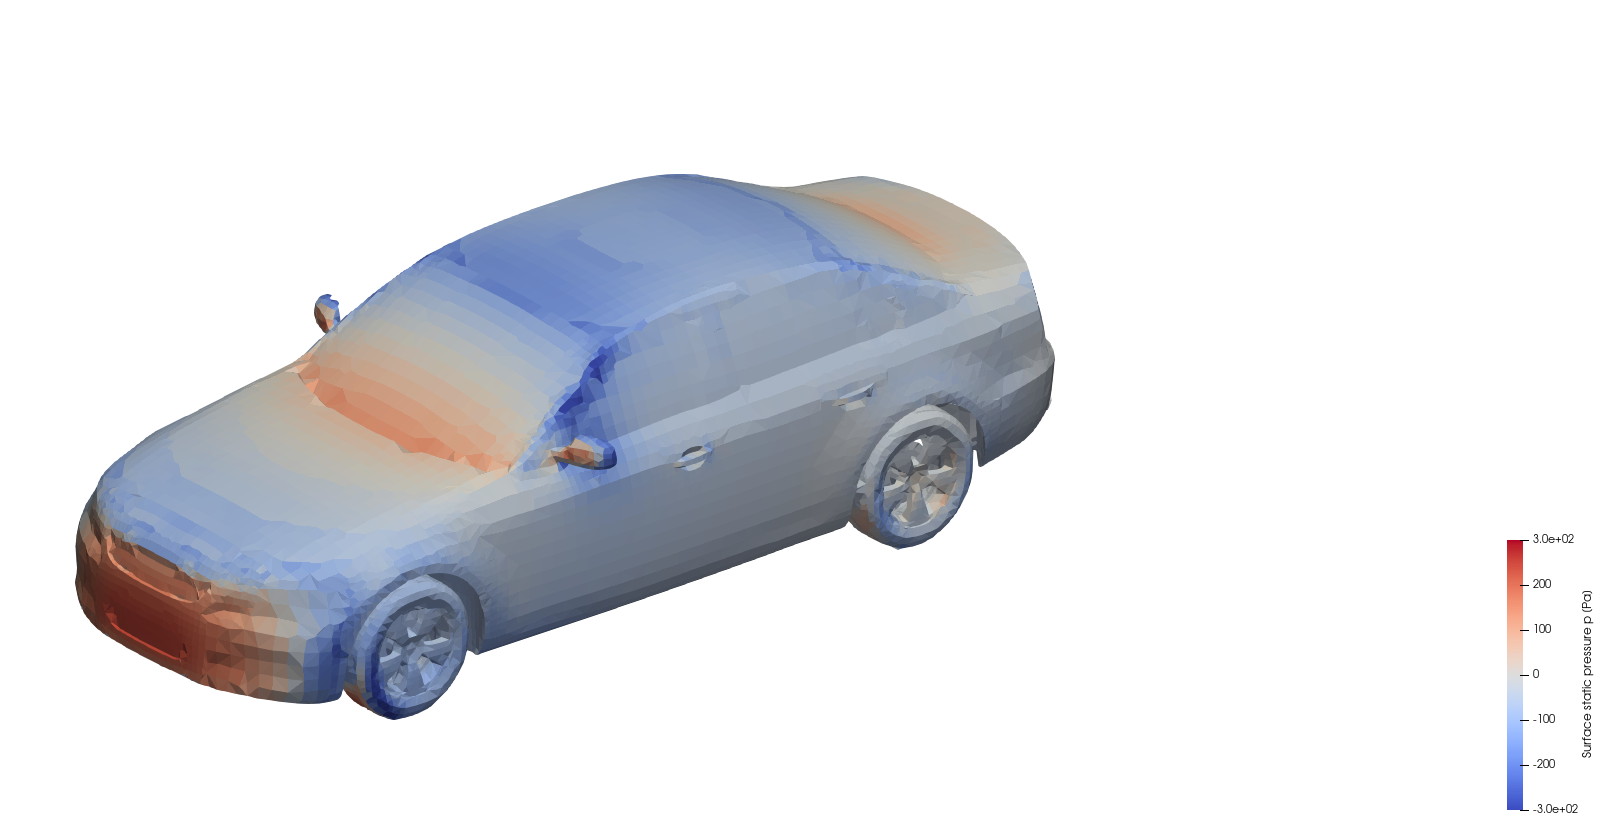
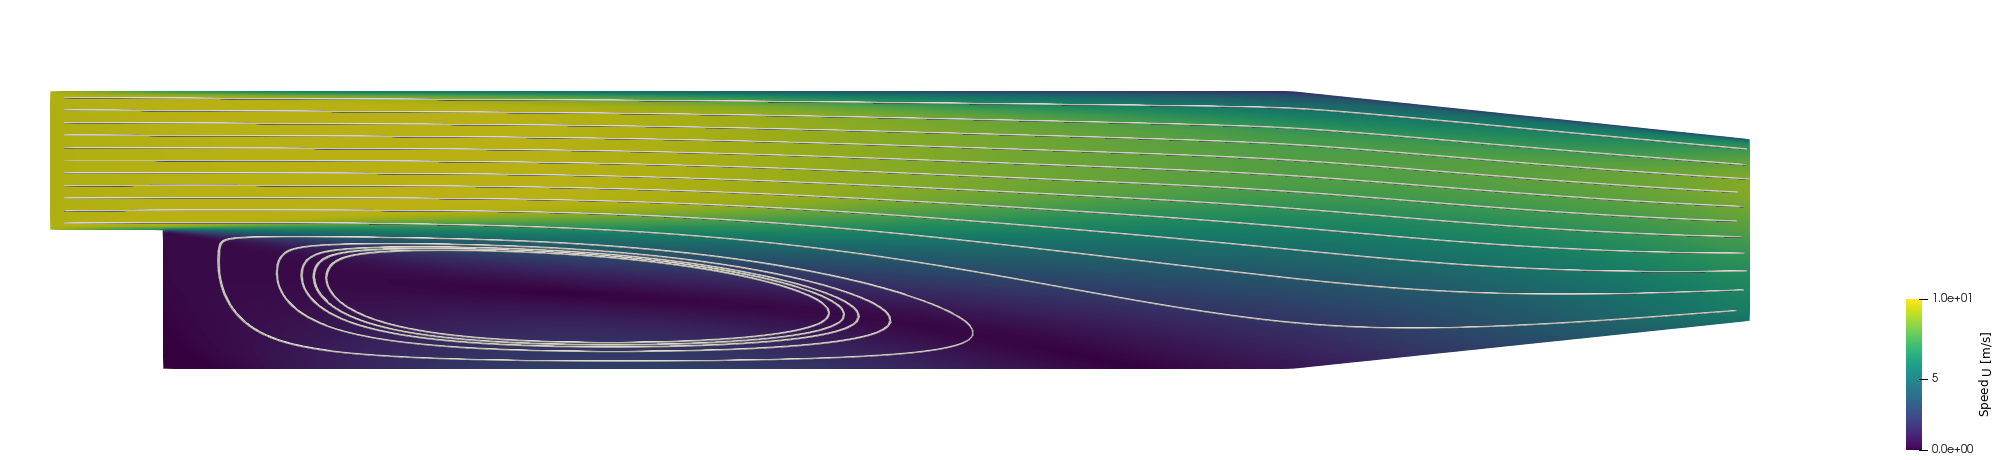
New simulation results unavailable
Geometry-only declarations and eight native previews are available below. The separate numerical review has not established an accepted new baseline/spoiler CFD result or any geometry-variation scientific point.
No drag curve, interpolated simulation or invented render is shown. The images above are existing saved results, and the new gallery below contains geometry only; neither is an accepted new geometry-variation CFD study. The hosted candidate does not execute CFD solvers or accept full industrial datasets.
Rendered 23 October 2026. DrivAer: 92,316 cells, no boundary layers, 500 iterations without meeting residual targets. The full case and private input documents are not distributed. These renders do not validate flow physics or establish hosted admission for an industrial case.
Inspect curated image hashes and provenance ↗Local saved-results example · ParaView
The agent declares the saved-results reader, centreline slice, pressure field, style and image output. Schemaxis runs ParaView and retains the artifact and receipt.
UNRESOLVED diagnosticJob 5919 · steady iteration 3847, not seconds
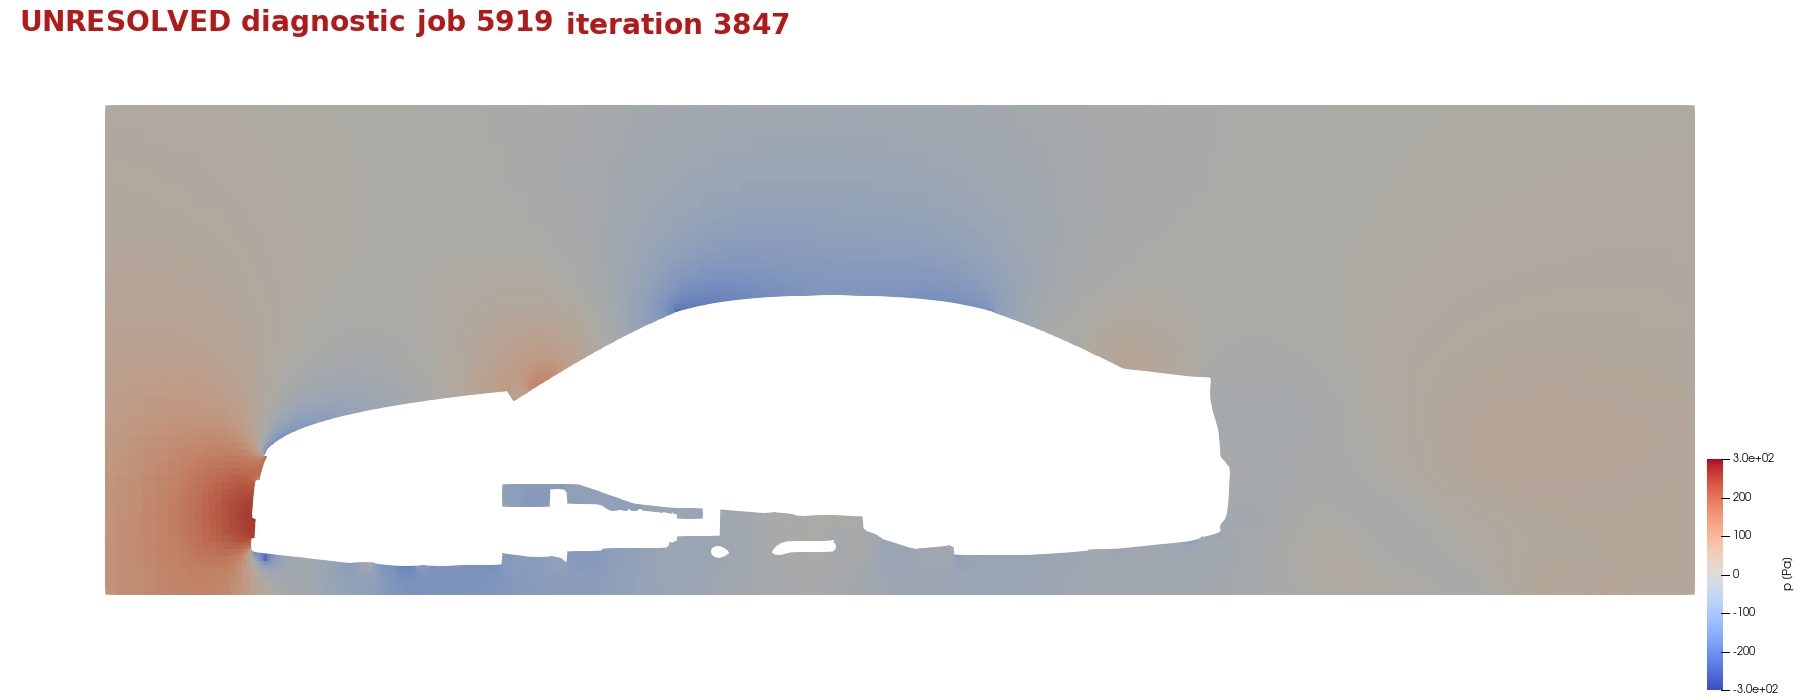
Saved-results illustration only. Numerical status remains unresolved; this is not an accepted aerodynamic or geometry comparison, validation or optimisation result. This local ParaView example is outside the hosted 512 KiB pilot; CFD solver and setup work are not a service offered here.
Saved iteration3847 from a steady incompressible kOmegaSST DrivAer baseline. Native numerical status UNRESOLVED: Uy residual and lift-stationarity limits missed. Iteration is not seconds. p is physical static gauge pressure in Pa; outlet reference0, no density conversion. The solid vehicle has no fluid cells in the slice. This single-mesh illustration is not an accepted aerodynamic comparison, validation, grid-independence result or geometry-optimisation evidence. No spoiler or pylons. Cell slice values are displayed without cell-to-point smoothing. Presentation r2 uses−300…300Pa over the complete displayed centreline slice; lower pressure exists elsewhere in the whole volume outside this view. Full-volume and displayed-slice ranges are retained separately. Tighter camera/window and banner revise presentation only, after the preserved r1 visual rejection; no favourable scientific-result selection or validation claim.
Native rendering and the fresh artifact check passed. Those checks establish the retained image and declared rendering; they do not accept the CFD solution. The runtime self-reported ParaView 5.13.3; this local observation does not qualify the hosted pilot or other runtimes.
PNG SHA-256: ac6576508325bc9a66f38145db0bad8b9b9a5e5c946e82b2041b86ca27b6b101
Declared inputs · separate from saved flow results
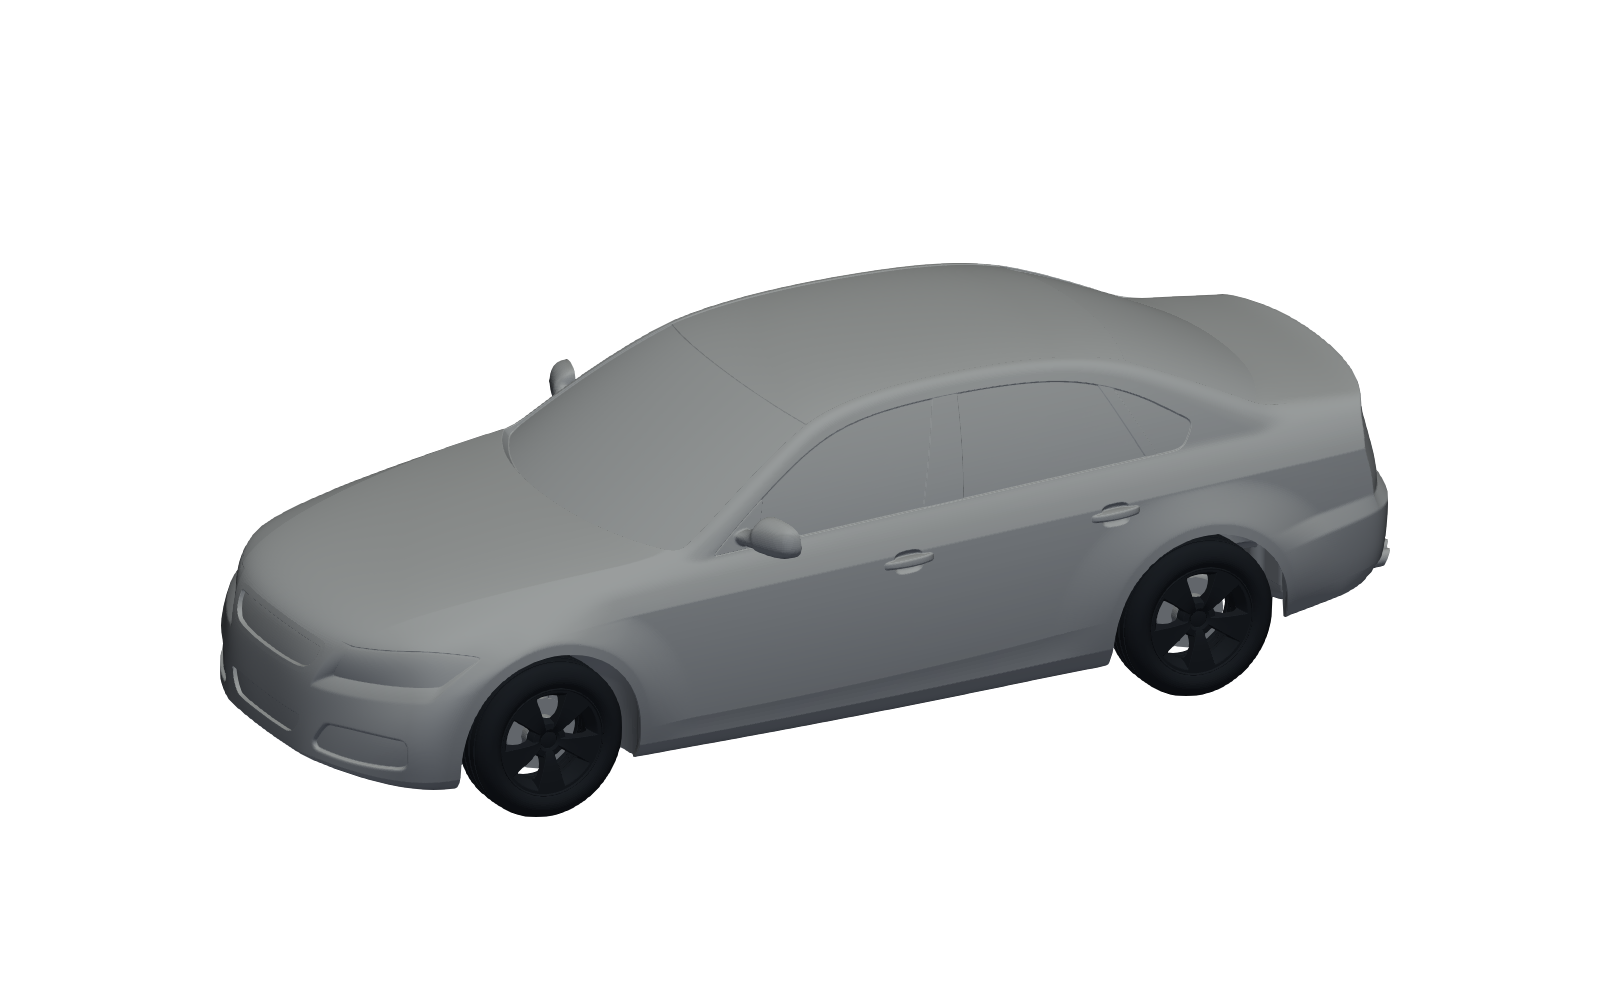
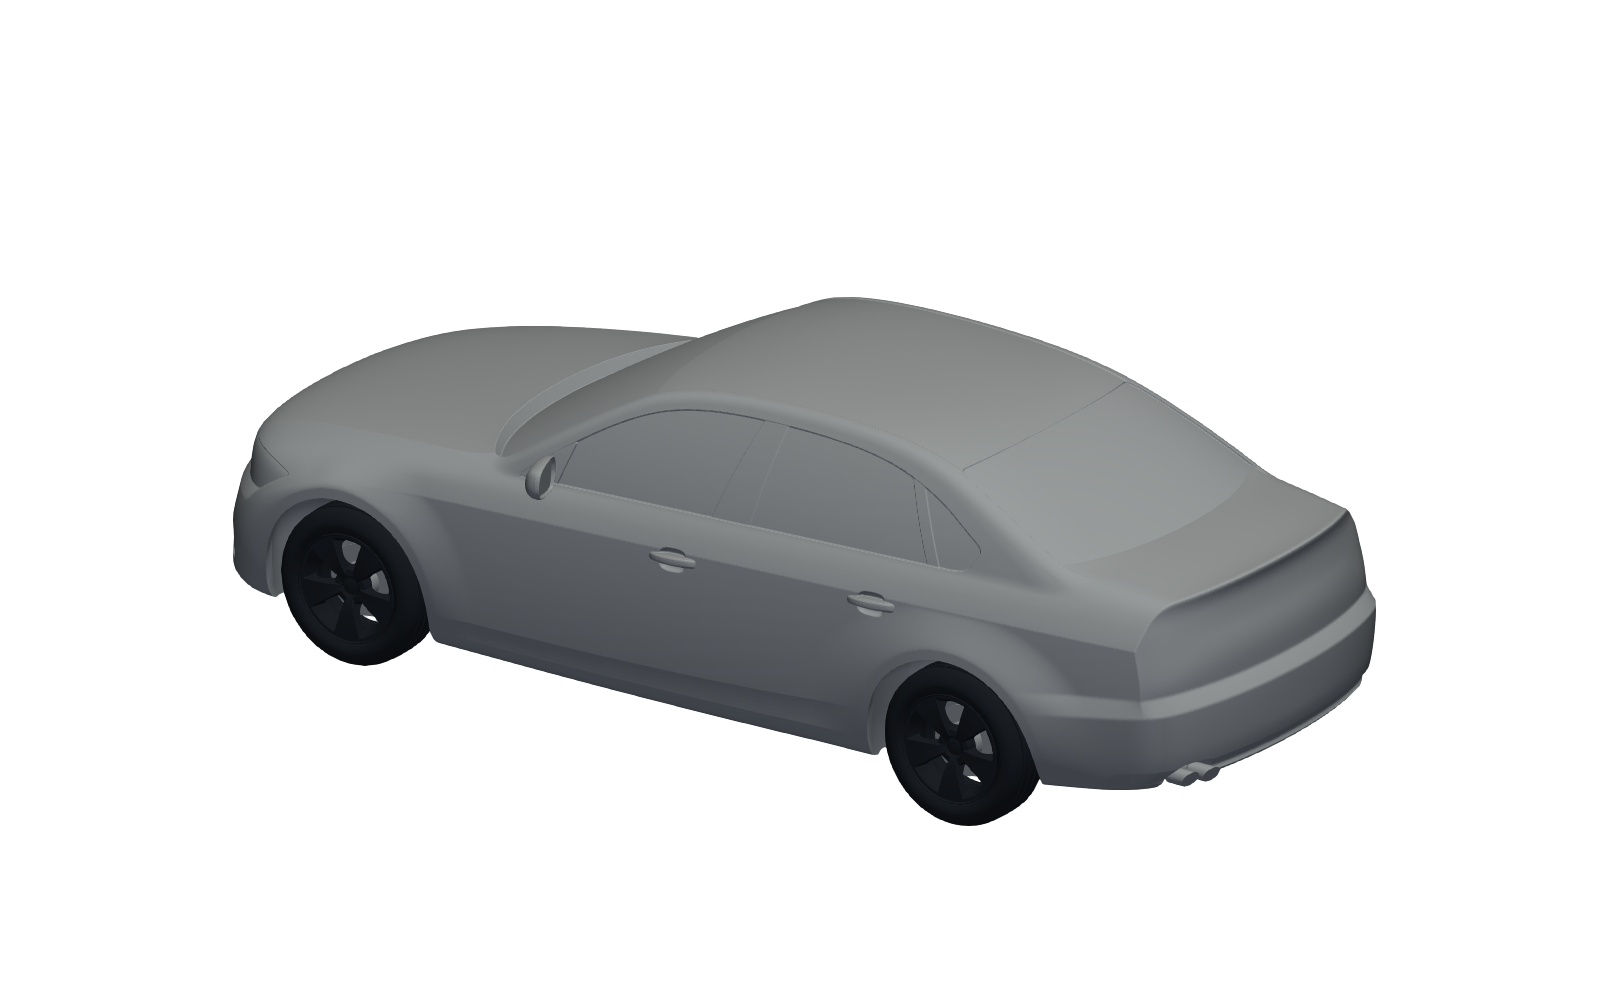
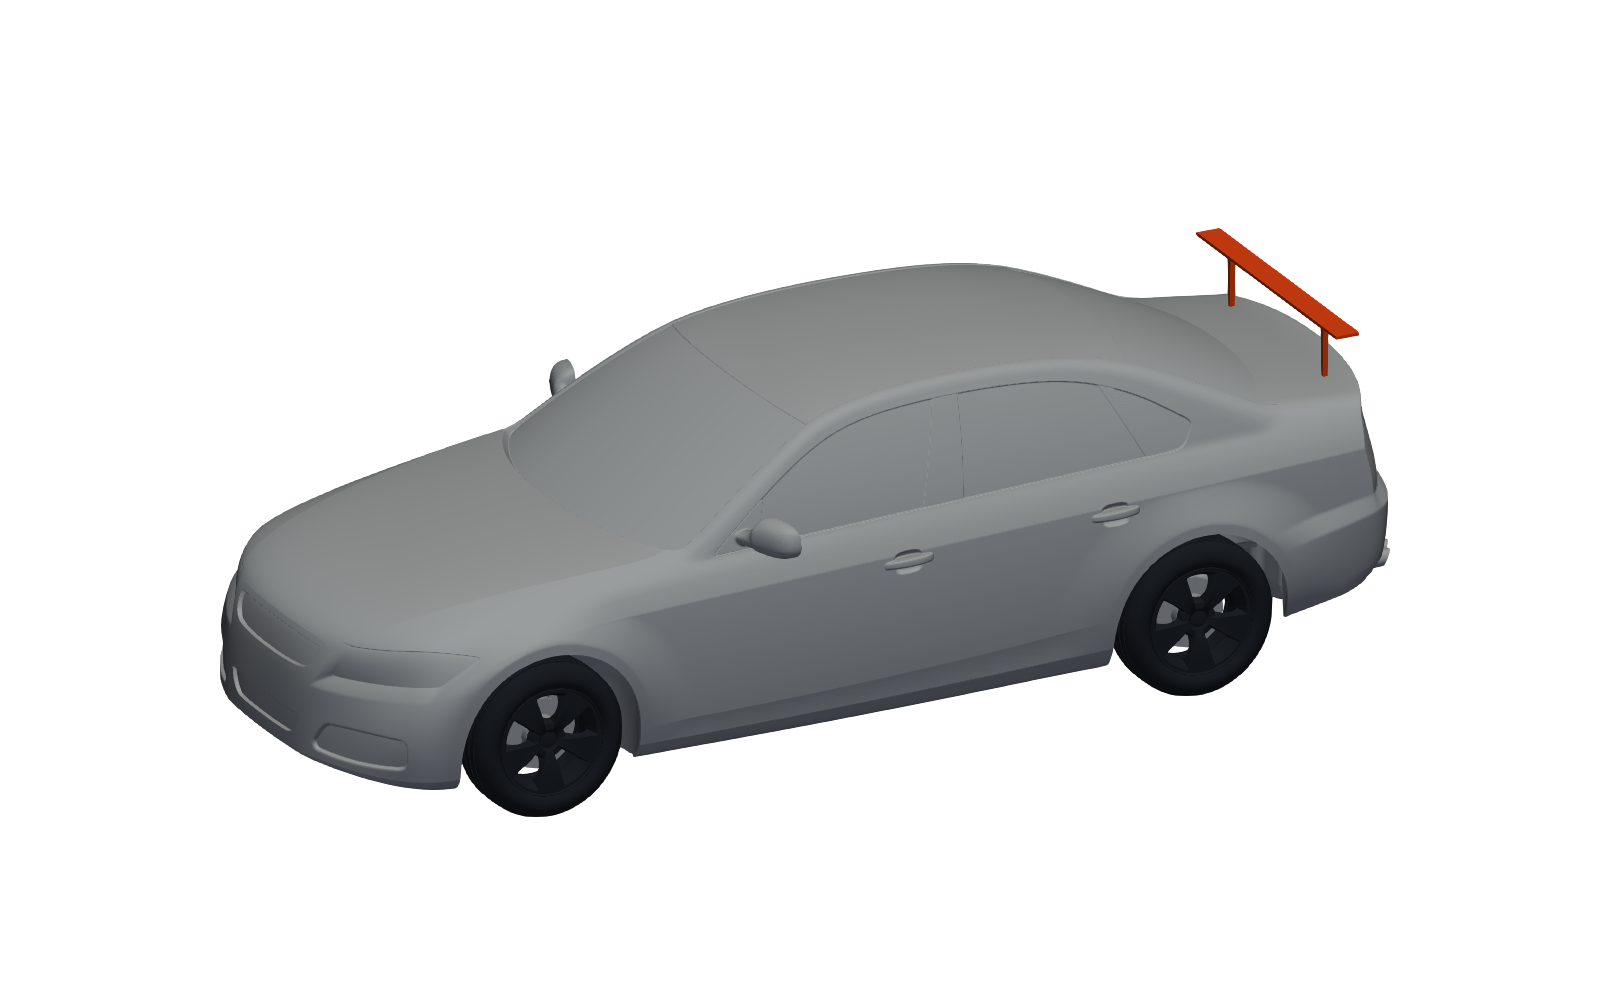
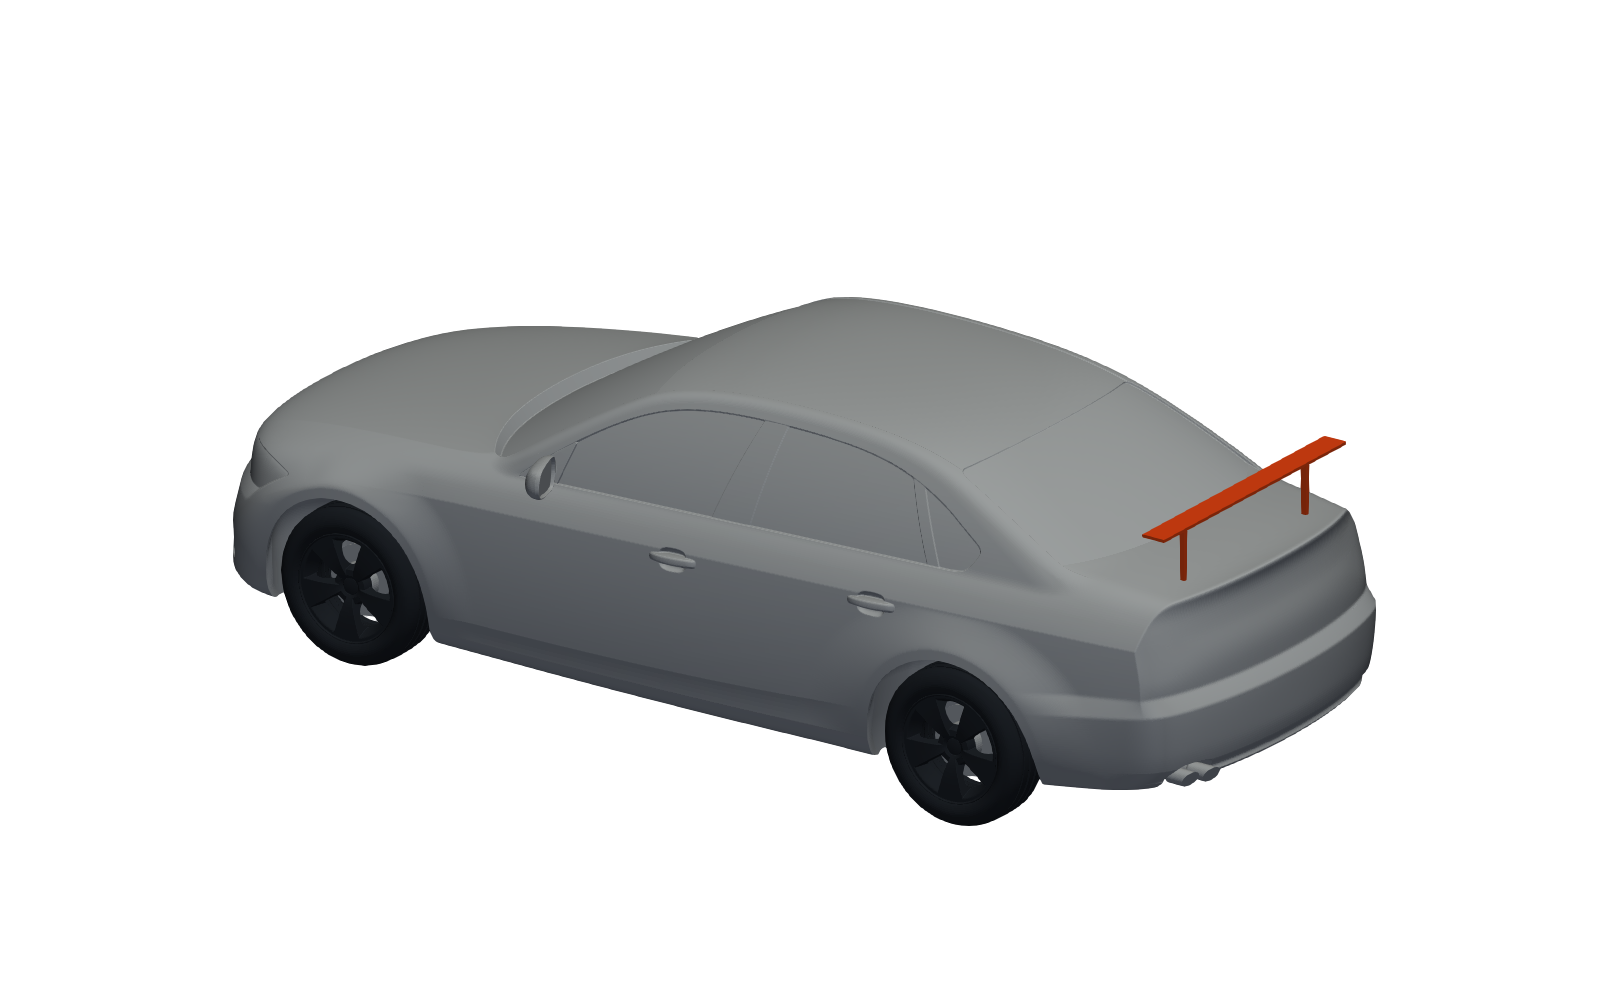
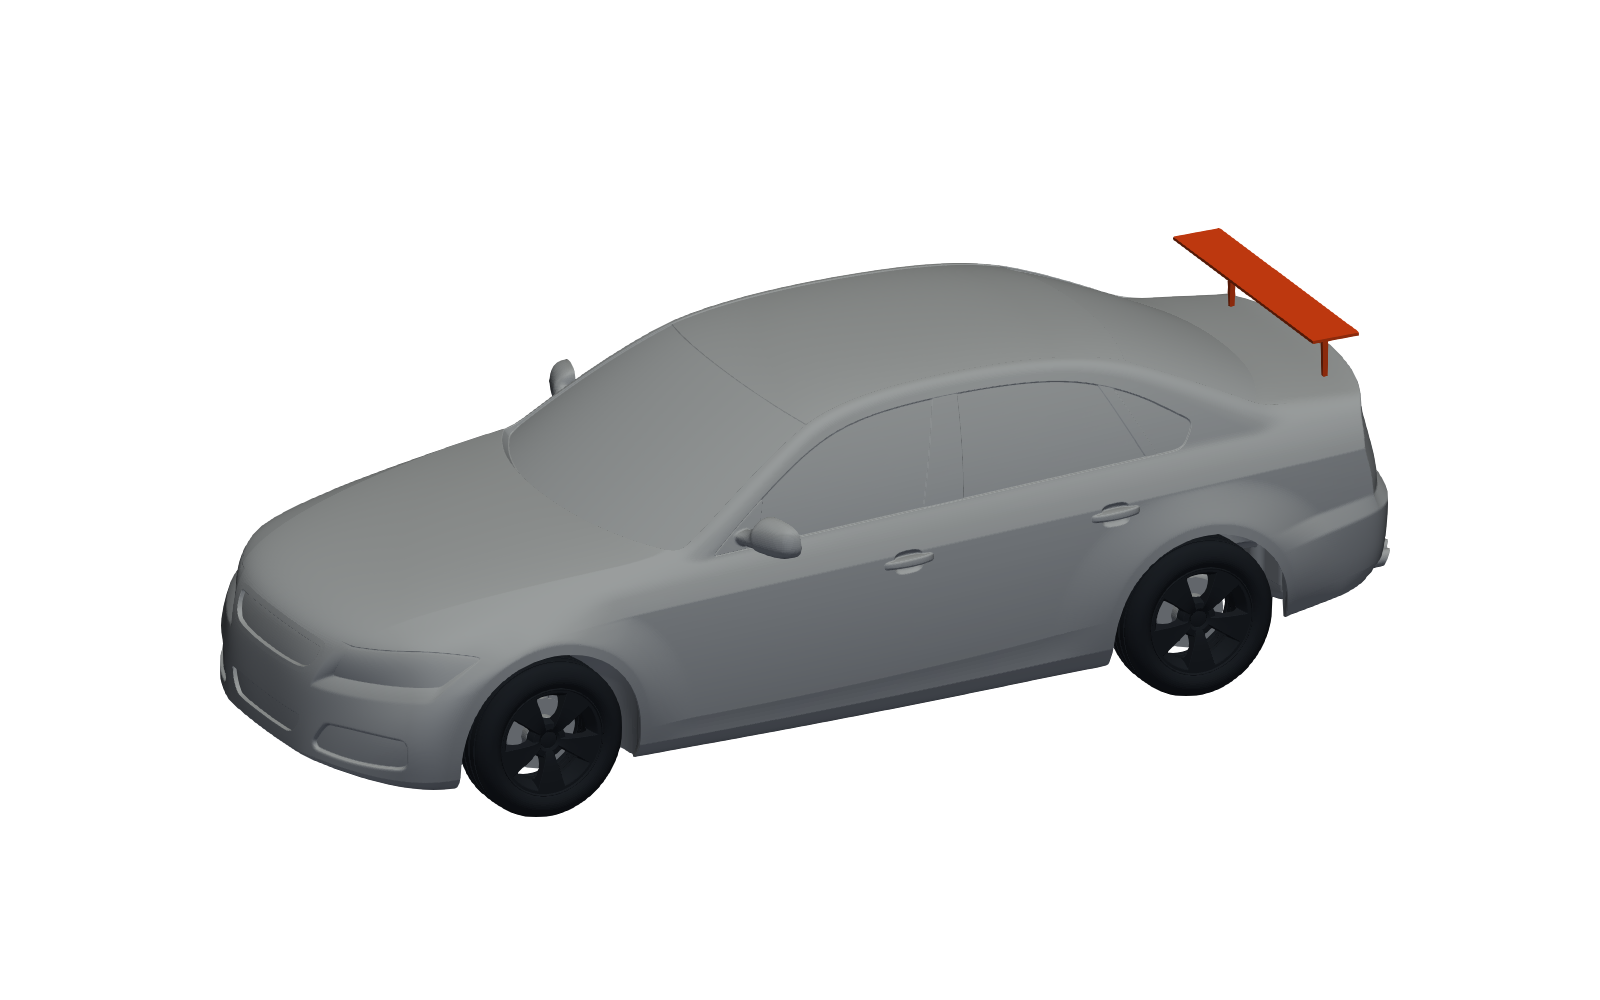
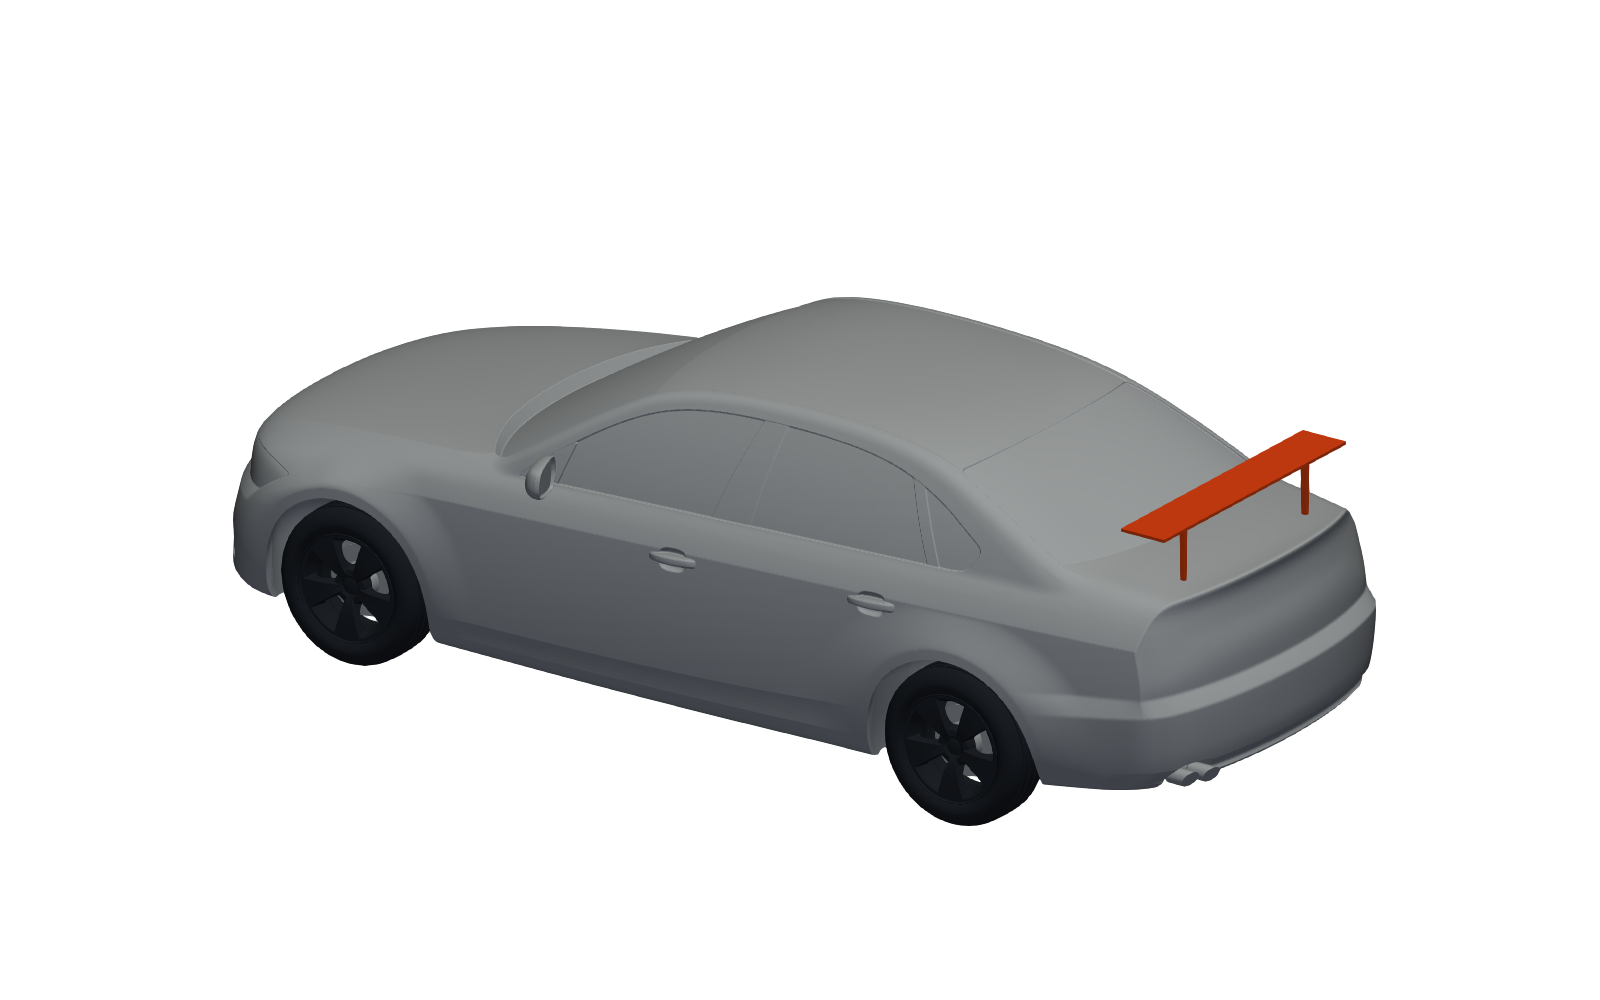
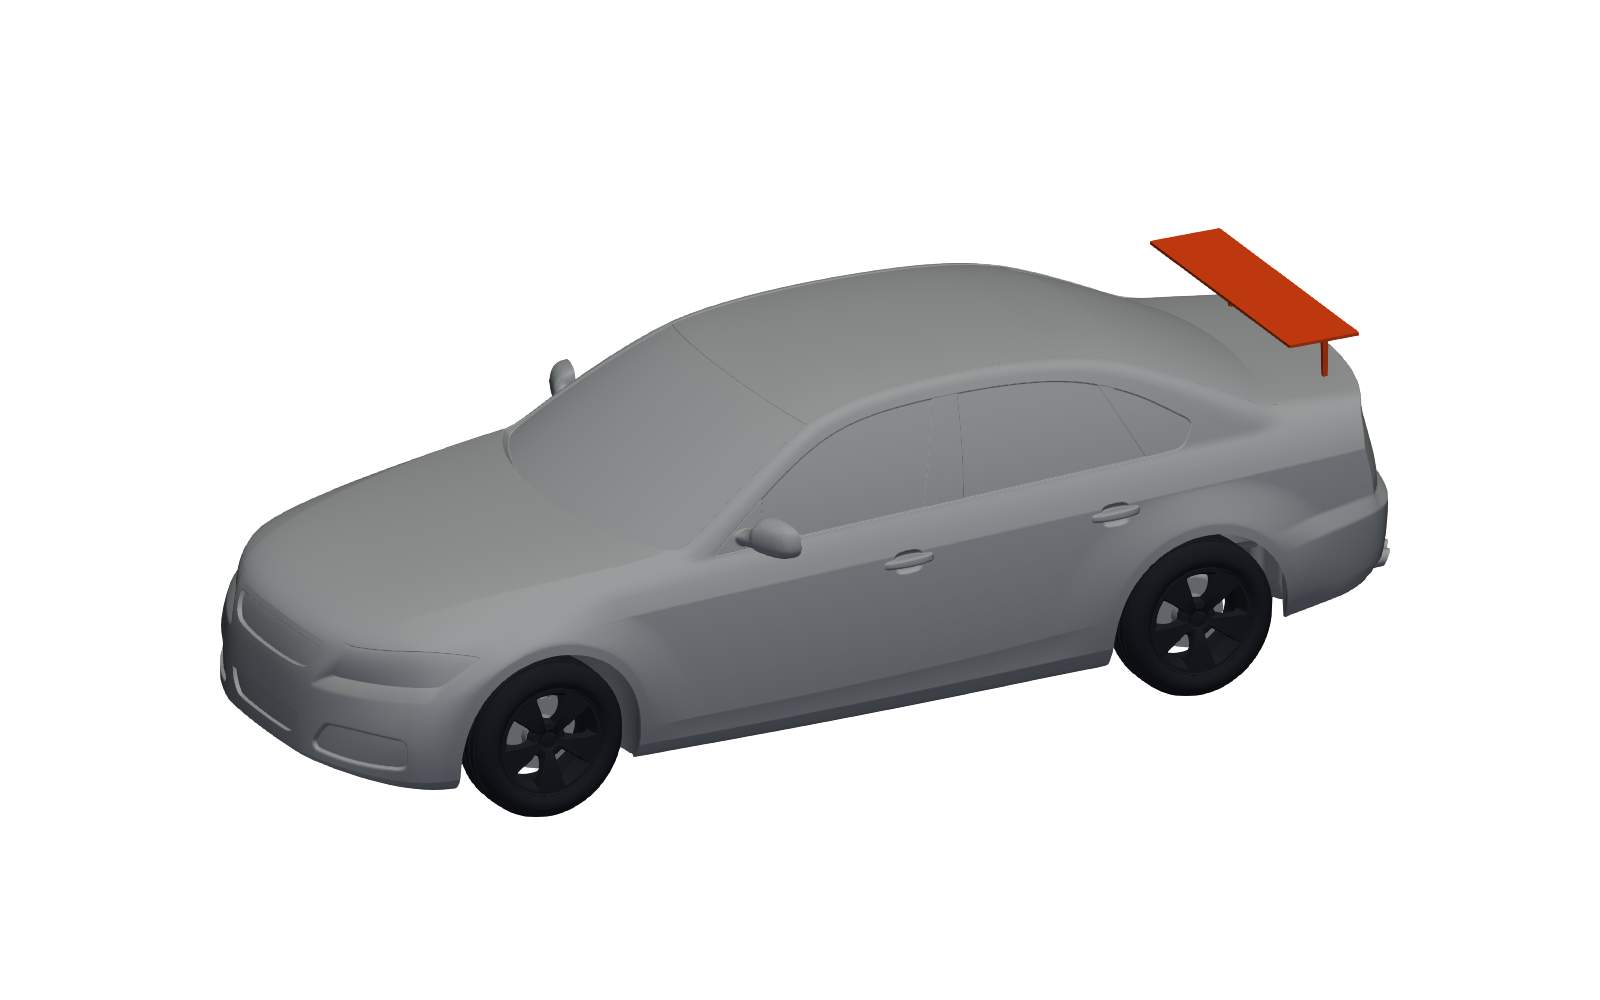
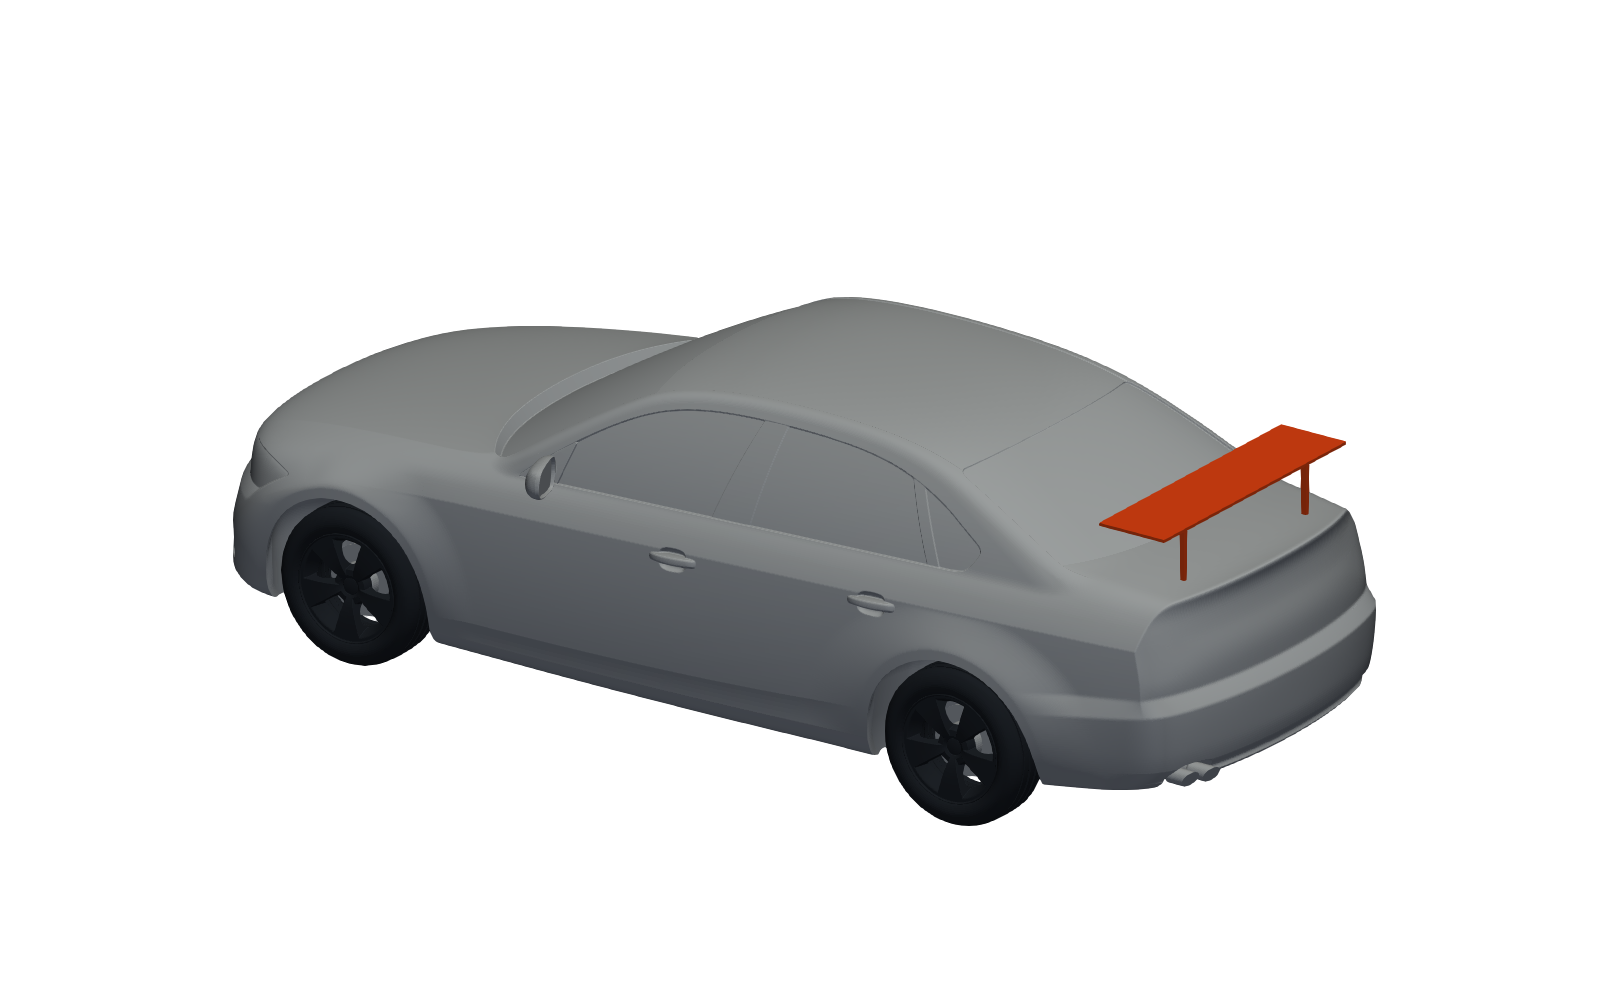
Eight genuine native previews: baseline without a spoiler, then 100, 200 and 300 mm plate chords, each viewed from common front/rear orthographic cameras. These images show geometry inputs, not a CFD study.
GEOMETRY ONLY · NO ACCEPTED CFD RESULTS
Genuine DrivAer body and wheels with constructed orange plate/pylons where enabled; not AI-generated pictures. Baseline has no plate or pylons, and its chord/span are not applicable.
There is no accepted new fluid mesh, flow field, force result, simulation-variant run or geometry-variation scientific graph here. The existing saved-flow gallery above keeps its original coarse/unconverged labels. This does not add a hosted CFD solver or change the hosted input limit.
Geometry is in metres with identity transform. Float32 STL is a display approximation: original topology warnings are retained, and no repair, union, watertightness or topology qualification is inferred. No mesher may use these preview STLs. Only the approved PNGs are available here.
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. No spoiler: no plate and no pylons; chord/span not applicable. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
be583062fd2860d4a4a53af851e73fe7e0cb792c4f2f02e22291b199fc0c0ea5
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. No spoiler: no plate and no pylons; chord/span not applicable. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
4d7abd5b0ed94a0832728a04e55d13c5ad81a558c831454c32672819e9e3c139
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 100 mm, span1.2 m; nominal plate PLANFORM area 0.12 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
cf74025fc0bd3a207e4f37dc811afe789453d23d2cdd7af82019357f82434d10
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 100 mm, span1.2 m; nominal plate PLANFORM area 0.12 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
7995cb1ce4446bb2683d4aec0b5450b57c9595212efa908fe62417bac74e91e7
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 200 mm, span1.2 m; nominal plate PLANFORM area 0.24 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
985912e76ad3127964757771656f838fbfadf6dff16fec59d79307613c949d7a
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 200 mm, span1.2 m; nominal plate PLANFORM area 0.24 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
f979eb76029e2d5d201104008ccac92ee1b8962b3c5d962334c9d2aaa6c32a35
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 300 mm, span1.2 m; nominal plate PLANFORM area 0.36 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
938ad6a955351d9dc9bf674bb482dd6e54642f805fca9ec9aa62c138287332f2
DECLARED INPUT GEOMETRY · GEOMETRY ONLY
Geometry only — not a fluid mesh, CFD field, force result or accepted simulation/variant run.
Planform = span × chord, excluding pylons; not wetted, exposed or total-device surface area.
GEOMETRY_ONLY_NOT_SIMULATION_RESULTS. Plate chord 300 mm, span1.2 m; nominal plate PLANFORM area 0.36 m² (span×chord), excluding pylons, not wetted/exposed or total-device area. Genuine DrivAer body/wheels in metres, identity transform. Grey body, dark wheels; when enabled, orange plate/pylons. Common orthographic cameras. Float32 STL is a display approximation; no repair/union/topology qualification. Original body/wheel topology warnings retained. This is declared input geometry, not a fluid mesh, CFD field, force result or accepted simulation; no mesher may use these preview STLs.
Native render of genuine DrivAer body/wheels and constructed appendages; not AI-generated.
f0a5255082568132acd7b676633044b3f973f78085be918137679a9288c9e165
Second example · SymPy
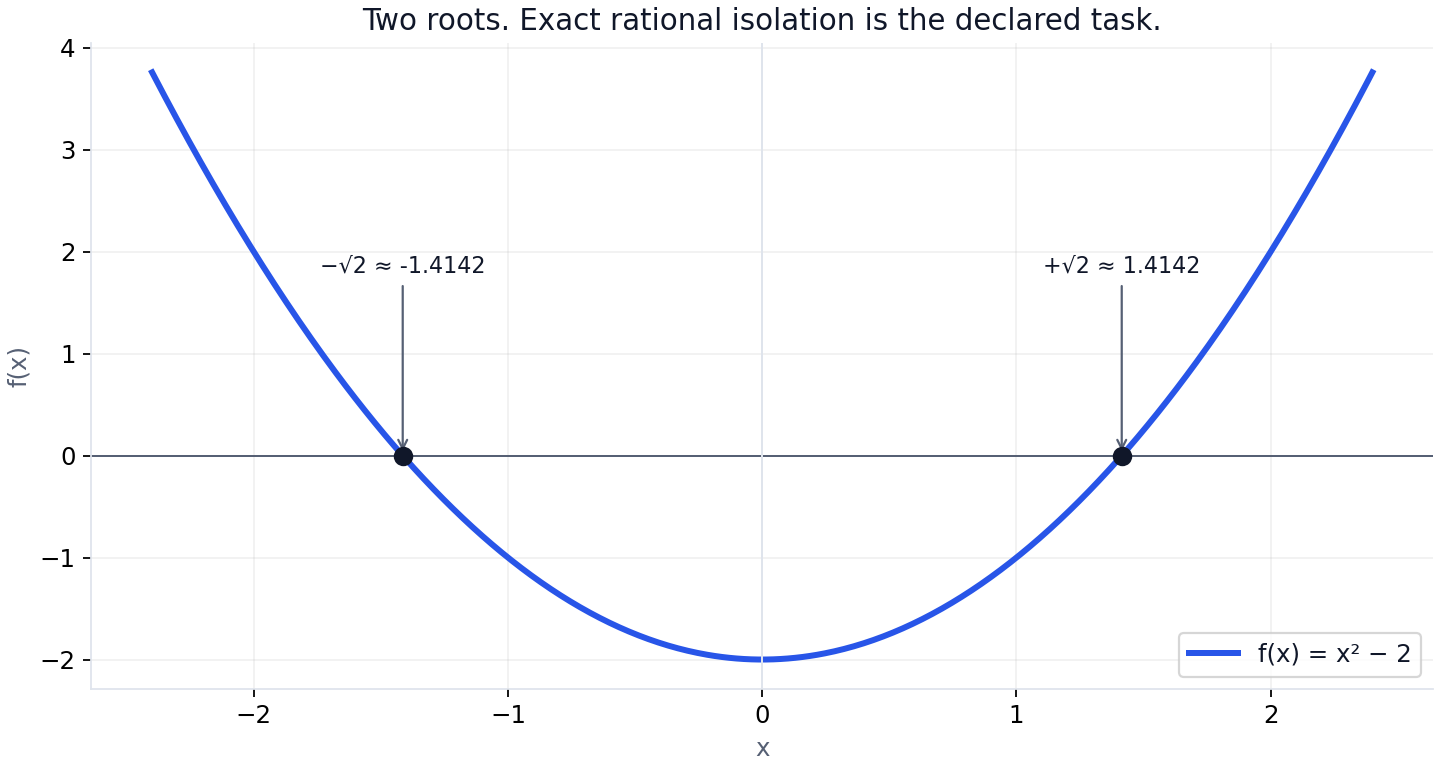
The same declared root-isolation workflow can be bound to new exact-rational coefficients. The picture is a mathematical illustration; the file explorer above includes real host-preflight records, not a new native run.
01 / Plan · illustrative
Discover the admitted operation, declare inputs and bounds, then inspect the plan and its revision. A valid plan is permission to attempt that declared work.
provider: sympy
operation: isolateRealRoots
polynomial: x² − 2
inputs: exact rational coefficients
The interactive file viewer above includes the exact template, recipe, parameter files and two recorded host plans. Both cases were bound and planned without launching SymPy.
Return to the workflow files ↑ Open the full reference ↗Choose how you operate it
A saved recipe and ongoing provider-operated access are different things. Neither a GUI paywall nor a database subscription is being introduced here.
Planned Apache-2.0 distribution includes declared workflow tooling, Studio, parameter forms, local execution and evidence. Operate it on your own machines with suitable application runtimes.
Read the current boundary ↗One reviewed declaration plus bounded parameters can describe a family of repeated jobs. A maintained commercial workflow pack is a proposal, not an included template library or adopted subscription.
Inspect a real example ↗The provider operates the supported runtime during agreed access. The earlier C$400 / 14-day proposal is under review; there is no final price, current hosted access or established buyer value.
Compare self-operation and hosting ↗